Ting-Hao Wang  (王霆皓)

I am a robotics enthusiast with a passion for mechanism design, mechatronics, and hands-on system integration. I am a Ph.D. candidate in Mechanical Engineering at the University of California, Berkeley, advised by Prof. Mark W. Mueller at the High Performance Robotics Lab (HiPeRLab). My research focuses on co-designing novel quadcopter configurations and efficient path-planning algorithms to achieve improved agility and stability in cluttered environments.

I earned my B.S. and M.S. from National Taiwan University, advised by Prof. Pei-Chun Lin in the Bio-inspired Robotics Lab (BioRoLa), where I developed TurboQuad, an innovative leg-wheel transformable robot capable of autonomous behavioral transitions according to the surroundings. My work spans the full stack from mechanical design and embedded systems to planning and control, driven by a love for building robots that work in the real world.
Ting-Hao Wang

Projects

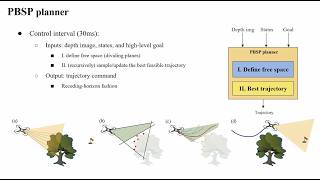
Plane-Based Spatial Partitioning for Computationally Efficient Quadcopter Trajectory Planning
A local trajectory planner for multicopters that uses depth sensors to partition space with planes, enabling 4× faster collision checking compared to voxel-based methods. Validated in Gazebo simulation and real-world autonomous flights in cluttered environments. Published at ICUAS 2026.
Quadcopter Motion Planning Depth Sensing Collision Checking
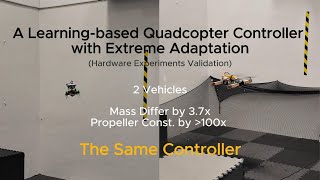
A Learning-based Quadcopter Controller with Extreme Adaptation
A reinforcement learning-based quadcopter controller capable of adapting in real time to extreme changes in system dynamics, including motor failures, payload variations, and structural damage, without requiring explicit fault detection or model updates. Published in IEEE T-RO 2025.
Quadcopter Reinforcement Learning Adaptive Control Fault Tolerance
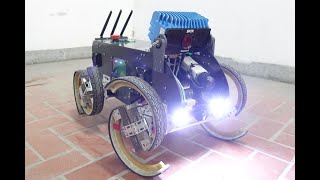
TurboQuad: A Leg-Wheel Transformable Quadruped Robot
A novel leg-wheel transformable robot capable of autonomous gait selection and obstacle avoidance using real-time RGBD visual feedback. Features a unique mechanism enabling agile transitions between wheeled and legged locomotion. Recognized as a top-3 finalist in the 2017 NI Global Student Design Showcase. The motion selection strategy developed for this platform was published in IEEE T-MECH, 2021.
Transformable Robot Gait Planning RGBD Vision CNN
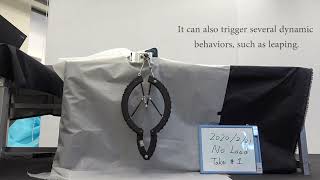
Development of a Novel Leg-Wheel Module with Fast Transformation and Leaping Capability
Designed a novel leg-wheel module enabling rapid, reliable transitions between wheeled and legged locomotion, along with a leaping capability for overcoming obstacles. The module was integrated into TurboQuad and validated through extensive experiments. Published in Mechanism and Machine Theory, 2021. The module design is protected under R.O.C. Patent I764563 (2022).
Mechanism Design Leg-Wheel Module Locomotion Mechatronics
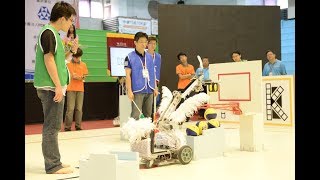
Autonomous Wheeled Robot with 7-DOF Robotic Arm
Built for the 2015 TDK Robocon, this fully autonomous wheeled robot integrates a 7-DOF arm with forward/inverse kinematics for trajectory planning and sensor-fused localization. The system completed multi-modal tasks including penmanship, color classification, and basketball shooting, earning 3rd place in the autonomous group.
7-DOF Arm Kinematics Sensor Fusion TDK Robocon
Inverted Pendulum Car
Designed and built a two-wheeled self-balancing vehicle based on the inverted pendulum model. Derived the equations of motion and performed stability analysis to characterize the system dynamics. Applied feedforward control to achieve robust balancing under external disturbances and varying loads, validating the controller through physical experiments.
Control Systems Feedforward Control Stability Analysis
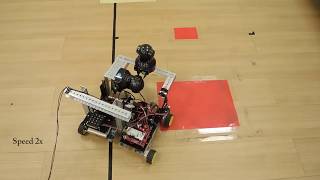
Autonomous Parking System
Developed a fully onboard autonomous parking system for a wheeled robot. Used real-time color-based image processing to detect and localize designated parking spaces in the environment. Planned and executed the parking maneuver autonomously, achieving accurate positioning without external computation or human intervention.
Computer Vision Image Processing Autonomous Navigation
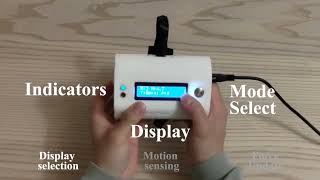
FlexiRehab: Portable Rehabilitation Feedback Module
A clip-on module that attaches to standard resistance bands to bring quantifiable, objective data to physical therapy. Using a built-in load cell and IMU, the device measures and records tension force, tracks pitch and angle of movement, auto-starts a timer, and counts repetitions via vertical acceleration, delivering real-time feedback on an onboard LCD display.
Mechatronics Load Cell IMU Rehabilitation Embedded Systems

Publications

  1. T.-H. Wang and M. W. Mueller, "Plane-Based Spatial Partitioning using Depth Sensors: Computationally Efficient Local Trajectory Planning for Multicopters over Obstacles," International Conference on Unmanned Aircraft Systems (ICUAS), 2026. pdfdoivideo
  2. D. Zhang, A. Loquercio, J. Tang, T.-H. Wang, J. Malik, M. W. Mueller, "A Learning-based Quadcopter Controller with Extreme Adaptation," IEEE Transactions on Robotics (T-RO), 2025. pdfdoivideo
  3. L. R. Rubi, J. Kam, R. Luo, J. Yang, X. Zheng, E. Zou, T.-H. Wang, M. W. Mueller, "UCAirLink: A VTOL-Based Air Transportation System for Optimizing Commuter Efficiency," Vertical Flight Society Forum Proceedings, 2025. pdfdoi
  4. T.-H. Wang and P.-C. Lin, "A Reduced-Order-Model-Based Motion Selection Strategy in a Leg-Wheel Transformable Robot," IEEE/ASME Transactions on Mechatronics (T-MECH), vol. 27, no. 5, pp. 3315–3321, 2021. pdfdoivideo
  5. H.-Y. Chen, T.-H. Wang, K.-C. Ho, C.-Y. Ko, P.-C. Lin, P.-C. Lin, "Development of a Novel Leg-Wheel Module with Fast Transformation and Leaping Capability," Mechanism and Machine Theory, vol. 163, 104348, 2021. pdfdoivideo
  6. C. Liu, T.-H. Wang, P.-C. Lin, "Development of an Innovative 2-DOF Continuous-Rotatable Mechanism," International Symposium on Robotics and Mechatronics (ISRM), vol. 78, pp. 125–137, 2019. pdfdoi
  7. S. L. Hsu, K. W. Liu, C. H. Hsiung, S. Y. Chen, T.-H. Wang, P.-C. Lin, "Flip-and-Leap in a Hexapod Robot," iRobotics, 2019. pdf
  8. T.-H. Wang, D. G. Sung, P.-C. Lin, "Terrain Classification, Navigation, and Gait Selection in a Leg-Wheel Transformable Robot Using Environmental RGBD Information," International Automatics Control Conference (CACS), 2018. pdfdoi

Patents

  1. P.-C. Lin, H.-Y. Chen, T.-H. Wang, "Wheel-Leg Hybrid Module with Rapid Transformation Capability," R.O.C. Patent I764563, 2022. patent